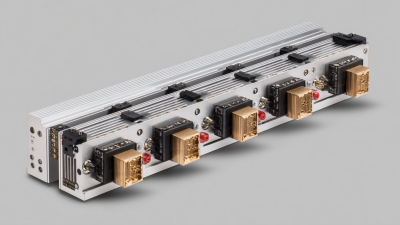
Choosing a miniature linear motor in 2026 requires more than comparing speed, stroke, and price. The device may fit inside a medical actuator, optical stage, laboratory sampler, or compact automation module. Yet each application exposes different limits. That choice matters.
Industry forecasts support this growing need for precise, space-efficient motion. Grand View Research identifies automation, electronics, and medical equipment as important drivers of the global linear motor market. MarketsandMarkets also projects continued market expansion through the decade, linked to robotics, semiconductor equipment, and factory automation. These reports differ in market definitions and forecast values. That difference deserves attention. A forecast is evidence, not a guarantee.
The best miniature linear motor should match the complete motion profile, not one impressive specification. Examine continuous force, peak force, stroke length, acceleration, repeatability, thermal behavior, and duty cycle. Check whether the motor needs an encoder, external guide, controller, or active cooling. A short 20-millimeter stroke can still generate demanding thermal loads during rapid cycling. Connector size and cable flexibility may also decide whether installation succeeds.
Industry standards such as ISO 9283 can help evaluate positioning performance, although the test setup may not represent your machine. In practical selection, request measured curves, test conditions, lifetime data, and control compatibility from the manufacturer. Specs can mislead. A smaller motor is not automatically more efficient. This guide explains how to compare a miniature linear motor with greater technical discipline, while acknowledging that real-world validation remains essential.
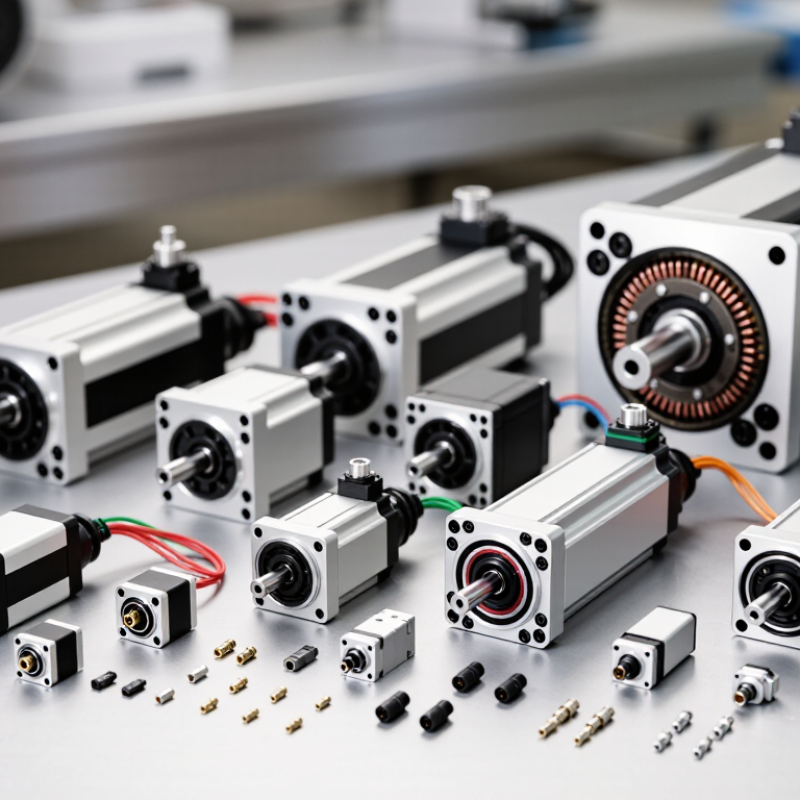
How to Choose the Best Miniature Linear Motor in 2026?
Define Miniature Linear Motors and Their Core Operating Principles
A miniature linear motor converts electrical energy directly into straight-line motion. Unlike a rotary motor with a lead screw, it does not need mechanical conversion. Its moving element travels along a guide, driven by electromagnetic force. In many designs, current passes through coils while permanent magnets create the magnetic field. The interaction produces thrust, acceleration, and controlled positioning.
The term is not perfectly standardized. That matters. Some suppliers describe compact voice-coil actuators as linear motors, while others mean brushless, multi-phase systems. A voice-coil model usually offers short stroke and simple force control. A multi-phase motor can deliver continuous motion, higher speed, and better precision. Feedback sensors then report position to the controller, correcting small errors during movement.
Industry data shows why this technology is receiving attention. Grand View Research estimated the global linear motor market at about USD 1.3 billion in 2023, with continued growth through 2030. MarketsandMarkets also identifies automation, semiconductor equipment, and medical devices as important demand areas. These figures describe the wider market, not miniature units alone.
A practical evaluation should examine continuous force, peak force, stroke, speed, heat, and repeatability. Check the operating temperature too. A small motor may reach impressive acceleration, yet lose force after several rapid cycles. That weakness is easy to miss. The best choice depends on the load, duty cycle, guide friction, and required feedback resolution. Specifications help, but real testing remains necessary.
Define miniature linear motors and compare their core operating principles through representative usable stroke ranges.
How to Choose the Best Miniature Linear Motor in 2026?
Selecting a miniature linear motor starts with the motion profile, not the catalog size. For short, rapid strokes, voice-coil motors provide smooth force and simple control. Stepper-based linear motors suit repeatable positioning, but they may lose torque during acceleration. Linear servo motors fit demanding speed and accuracy targets. Piezoelectric actuators offer excellent resolution, though their travel is usually limited. The choice is rarely perfect.
Force and speed must be checked together. A motor rated for high peak force may overheat under continuous duty. Calculate moving mass, acceleration, friction, and duty cycle before comparing specifications. IFR’s World Robotics 2024 report recorded 541,302 industrial robot installations worldwide in 2023. That demand reflects tighter requirements for compact, responsive motion systems. Still, robot data does not automatically predict your application. A laboratory slide and a packaging axis behave differently.
Tips: Leave space for cables, sensors, and heat flow. Test the motor with the real load, not a simulated ideal. A 0.1 mm alignment error can create unwanted friction in a small mechanism. Check continuous force, peak force, stroke, repeatability, and environmental limits. According to IEC 60034-1, temperature rise and duty conditions affect motor selection. I would also question every “maximum” value. It may describe a brief test, not dependable daily performance.
How to Choose the Best Miniature Linear Motor in 2026?
Precision starts with the application, not the catalog headline. Check repeatability, straightness, backlash, and positioning error under real loads. A motor that reaches 1 micrometer on paper may drift after continuous cycling. In bench testing, measure the carriage at cold start and after one hour. Use the same payload, speed, and acceleration. The 2024 World Robotics report recorded 541,302 industrial robot installations in 2023, according to the International Federation of Robotics. That growth increases demand for compact actuators with stable, repeatable motion. Yet robot statistics do not prove miniature motor accuracy. That distinction matters.
Control quality depends on the feedback device, drive resolution, and motion profile. Closed-loop feedback usually improves error correction, but tuning still requires care. Watch settling time, following error, and vibration near travel limits. Efficiency also deserves a wider definition. The U.S. Department of Energy estimates motor systems use about 23% of American electricity. A small actuator may consume little power, yet repeated rapid cycles can create significant energy and heat. Select low-resistance windings, efficient drives, and sensible acceleration limits. Thermal testing is essential. Record winding temperature, housing temperature, and nearby component temperature during the longest duty cycle. The International Electrotechnical Commission’s IEC 60034-1 framework provides useful temperature and rating guidance, although miniature linear motors may need additional application testing. I would not trust a single datasheet value. Real installations are messier.
The following comparison uses representative engineering ranges for compact linear-motion technologies. Actual performance depends on stroke length, load, duty cycle, feedback resolution, amplifier settings, cooling, and mechanical integration.
| Miniature Linear Motor Type | Typical Travel | Continuous / Peak Force | Repeatability | Positioning Resolution | Typical Maximum Speed | Control Requirements | Electrical Efficiency | Thermal Performance | Best-Fit Applications |
|---|---|---|---|---|---|---|---|---|---|
| Voice-Coil Linear Motor | 5–50 mm | 2–50 N / 5–120 N | ±2–10 µm with feedback | 0.1–1 µm with a suitable sensor | 0.5–2 m/s | Bidirectional current control; position feedback is recommended for accurate positioning | Typically 25–55% | Heat is generated continuously at standstill; force must be reduced or actively cooled during high-duty operation | Short-stroke focusing, valves, optical alignment, haptic mechanisms, and vibration control |
| Piezoelectric Stack Linear Actuator | 10–200 µm without amplification; up to several millimeters with a flexure or mechanical amplifier | 10–1,000 N / 20–2,000 N | Nanometer to sub-micrometer range with closed-loop feedback | Below 10 nm is achievable in well-designed closed-loop systems | 0.1–20 mm/s for precision positioning | High-voltage, low-current amplifier; hysteresis and creep compensation are normally required | Typically 5–30% | Low average heat at low frequency, but dielectric loss and amplifier heat can become important at high operating frequency | Semiconductor inspection, nanopositioning, microscopy, micro-dosing, and precision optics |
| Tubular Permanent-Magnet Linear Motor | 20–300 mm | 5–100 N / 15–300 N | ±1–5 µm with linear feedback | 0.1–1 µm, depending on encoder and servo tuning | 0.5–3 m/s | Three-phase or commutated current control with position feedback for high precision | Typically 60–85% | Good force density and no mechanical contact; continuous force is limited mainly by coil temperature and heat dissipation | Compact automation axes, pick-and-place systems, laboratory stages, and precision transport |
| Ironless Flat Linear Motor | 25–1,000 mm | 10–250 N / 30–800 N | ±0.5–3 µm with a linear encoder | 0.05–0.5 µm in a properly tuned servo system | 1–5 m/s | Three-phase servo drive, commutation feedback, and a linear scale for precision motion | Typically 65–90% | Very low cogging and smooth motion, but the coil assembly can heat quickly because it has limited thermal mass | High-speed inspection, electronic assembly, scanning stages, and precision manufacturing |
| Moving-Magnet Linear Actuator | 5–100 mm | 1–40 N / 3–100 N | ±3–15 µm with feedback | 0.2–2 µm with an appropriate sensor | 0.2–1.5 m/s | Simple current or servo control; closed-loop feedback is needed for accurate absolute positioning | Typically 35–65% | The stationary coil can be connected directly to a heat sink, making thermal management easier than in many moving-coil designs | Compact actuators, dampers, medical instruments, optical mechanisms, and low-to-medium duty automation |
| Miniature Stepper Linear Actuator | 10–300 mm | 2–80 N / 5–150 N | ±10–50 µm open loop; improved with feedback | Commonly 1–10 µm per commanded microstep, but load-dependent accuracy is lower | 10–300 mm/s | Pulse-and-direction drive; acceleration, resonance, and missed-step margins must be managed | Typically 20–50% | Current is often maintained while stationary, creating continuous heat; thermal derating is important in compact housings | Cost-sensitive positioning, laboratory equipment, compact Z-axes, and low-speed indexing |
| Selection guidance: Choose piezoelectric technology for nanometer-scale motion, voice-coil or moving-magnet designs for short-stroke dynamic control, tubular or ironless linear motors for high-speed precision, and miniature stepper actuators when simplicity and low initial system cost are more important than efficiency and servo accuracy. For continuous operation, compare force at the required duty cycle rather than peak force alone. | |||||||||
How to Choose the Best Miniature Linear Motor in 2026?
Material selection affects heat, stiffness, and alignment. Aluminum housings reduce weight, but expand about 23 µm/m·K. Steel expands roughly 12 µm/m·K. That difference matters in a 300 mm travel system. For repeated positioning, choose a rigid frame with controlled thermal paths. Copper windings improve conductivity, while high-grade magnets support stronger force density. However, stronger is not always better. Excess force can increase vibration and energy use.
Installation should match the machine, not the catalog image. An integrated guide saves space, but an external rail simplifies replacement. Side mounting suits narrow assemblies. Vertical mounting demands a brake or counterbalance, especially after power loss. Encoder feedback is valuable when tolerances are tight. A 2024 precision-automation market report from MarketsandMarkets links compact motion systems with rising demand for accurate, space-saving equipment. The report projects the broader linear motor market to grow at about 8% annually through 2028.
Reliability depends on duty cycle, dust exposure, cable routing, and heat removal. Check the rated life at your actual load, not only the headline specification. The U.S. Department of Energy’s Operations & Maintenance Best Practices Guide reports that preventive maintenance can reduce downtime and lower maintenance costs by 12–18%. Keep guides clean, inspect connectors, and record temperature trends. Small motors are easy to ignore. That is a mistake. A slightly oversized motor may be safer, but it can hide poor alignment and waste power. Recheck the design before ordering.
Selecting a miniature linear motor should begin with real testing, not attractive catalogue numbers. Define the required stroke, load, speed, accuracy, and duty cycle before comparing models. A motor that moves 2 kilograms slowly may fail under rapid, repeated movement. Test it at the expected voltage and temperature. Record thrust, positioning repeatability, noise, vibration, and heat after several operating cycles. One short demonstration proves very little.
Specifications reveal limits that testing may expose. Check continuous force instead of relying only on peak force. Review acceleration, backlash, mounting tolerances, cable flexibility, and controller compatibility. Ask for life-test conditions, measurement methods, and tolerance ranges. Independent verification is valuable when published data seems unusually perfect. It rarely is. My own early estimates have sometimes ignored heat buildup, causing performance to drift after extended use.
Total cost analysis should include more than the purchase price. Add the controller, power supply, mounting hardware, installation time, maintenance, energy use, and possible downtime. A cheaper motor can become expensive if it needs frequent replacement or complicated tuning. Calculate cost per operating hour over the expected service life. Leave room for uncertainty. Shipping changes, production delays, and small design revisions can affect the final figure. A clear spreadsheet often exposes these overlooked costs.
Sierramotion engineers help customers design solutions to complex motion problems. Whether a simple coil, or a precision motion assembly working in vacuum, Sierramotion has the experience to create a solution that works the first time.