Choosing a Robotic Gear manufacturer is not just a search for low prices or impressive catalog images. In a robot joint, gear teeth transfer force through repeated starts, stops, and changes of direction. Backlash, stiffness, noise, and heat can affect how smoothly an arm places a component or how steadily a mobile robot turns. Small details matter.
This guide introduces manufacturers serving global buyers and explains what to compare before requesting a quote. Look at product range, rated torque, reduction ratios, materials, customization options, and published test data. Ask how a supplier manages production consistency and what technical support is available after delivery. A clear datasheet is useful, but it does not replace checking whether a gearbox suits your load, duty cycle, mounting space, and operating temperature. That is not simple.
Supplier claims can be difficult to compare because testing methods and application assumptions may differ. Where possible, request drawings, traceable specifications, sample evaluation, and written clarification of warranty and lead times. These checks are practical, not guarantees. A gear unit that performs well on a light laboratory setup may behave differently under continuous industrial use. Buyers should confirm critical requirements with their engineering teams and the manufacturer before committing to volume orders. The goal is not to name one universal winner. It is to identify a reliable fit for the robot, production plan, and support needs at hand.
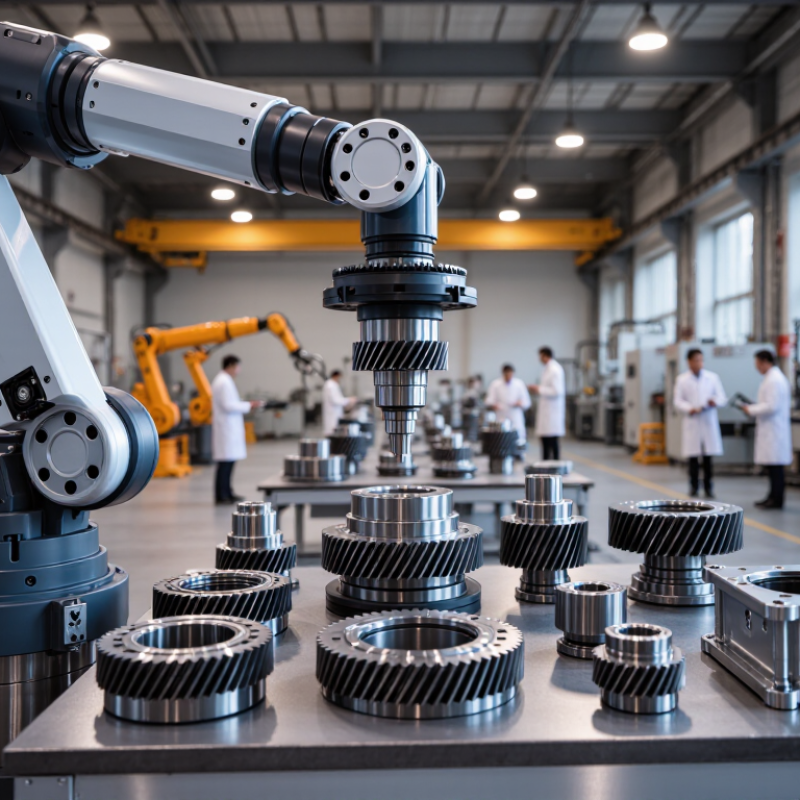
In an industrial robot, gears translate motor speed into controlled joint movement. A compact reducer can multiply torque, helping an arm lift a load without demanding an oversized motor. It also shapes positioning accuracy, stiffness, and response during repeated starts and stops. Small errors matter. Backlash can shift a gripper’s path, especially when a robot handles parts with tight tolerances. Gear selection therefore depends on payload, joint speed, duty cycle, and the required accuracy—not just the reduction ratio.
Demand makes this engineering choice increasingly important. The International Federation of Robotics reported 541,302 industrial robot installations in 2023, with 4,281,585 robots operating worldwide, in World Robotics 2024. That scale spans very different tasks, from fast packaging to precise assembly. Planetary, harmonic, and cycloidal reducers each offer different trade-offs in size, stiffness, efficiency, and backlash. Heat matters, too. A reducer that performs well in a brief test may behave differently during long shifts, when lubrication, mounting, and temperature affect wear. Datasheets help, but they cannot replace application-specific testing. A low-backlash rating alone is not a full answer. Buyers should compare torque capacity, allowable input speed, expected service life, and maintenance requirements under realistic operating conditions.
| Gear Type | Core Function in a Robot | Typical Characteristics | Common Applications | Key Buyer Checks |
|---|---|---|---|---|
| Strain-wave (harmonic) gear | Provides substantial speed reduction and precise, compact motion at robot joints. | Uses a flexible spline, circular spline, and wave generator. Its coaxial arrangement and low backlash make it suitable for compact joint designs. | Collaborative robots, lightweight articulated arms, and precision joints where low backlash and compact size are priorities. | Check rated torque, allowable moment load, torsional stiffness, backlash specification, service life, and lubrication requirements. |
| Cycloidal reducer | Reduces motor speed while transmitting high torque through rolling contact and multiple load-sharing elements. | Often offers high shock-load capacity and a compact reduction stage. Actual backlash, efficiency, and stiffness depend on design and manufacturing tolerances. | Industrial robot axes, positioning systems, and applications subject to variable or impact loading. | Compare rated and peak torque, allowable radial and axial loads, lost motion, vibration, sealing, and maintenance intervals. |
| Planetary gearbox | Combines speed reduction with torque transmission in a compact, coaxial assembly. | Planet gears share load around a central sun gear. Multiple stages can provide greater reduction; backlash and efficiency vary by construction. | Robot joints, servo-driven axes, mobile robot drives, and auxiliary positioning mechanisms. | Review reduction ratio, rated output torque, backlash, torsional stiffness, input speed, efficiency, and mounting interface. |
| Spur or helical gear train | Transfers rotary motion between shafts and can provide speed or torque changes in an actuator or transmission stage. | Spur gears have straight teeth; helical gears have angled teeth and generally engage more gradually. Helical gearing produces axial thrust that must be supported. | Robot joint transmissions, grippers, conveyor mechanisms, and other gear stages with suitable packaging and load requirements. | Assess gear ratio, tooth strength, noise, backlash, lubrication, bearing support, and—in helical designs—axial load capacity. |
| Bevel gear set | Changes the direction of rotary motion, commonly between intersecting shafts. | Tooth geometry and shaft arrangement determine load capacity, efficiency, and noise. Alignment and bearing support are important to performance. | Right-angle robot drives, wrist mechanisms, and compact motion systems that need to redirect power. | Confirm shaft angle, ratio, torque rating, mounting accuracy, backlash, lubrication, and support for gear-generated loads. |
| Worm gear set | Provides large speed reduction between non-parallel, non-intersecting shafts. | Can be compact and may resist back-driving under certain design conditions. Sliding contact can increase heat and reduce efficiency compared with some alternatives. | Positioning or auxiliary mechanisms where right-angle transmission and the required holding behavior suit the application. | Verify efficiency, thermal limits, lubrication, wear characteristics, backlash, and whether a separate brake is required for safe holding. |
© 2024 Sierramotion. All Rights Reserved